File "D:\Gits\DASH\cmf\_functions.py", line 365, in findMeshCollision
collisionDetection = vtkSRCP.vtkCollisionDetectionFilter()
AttributeError: module 'vtkSlicerRtCommonPython' has no attribute 'vtkCollisionDetectionFilter'
```
Either way, the function seems work thus far…

```auto
No Collisions Detected
(False, 0)
```
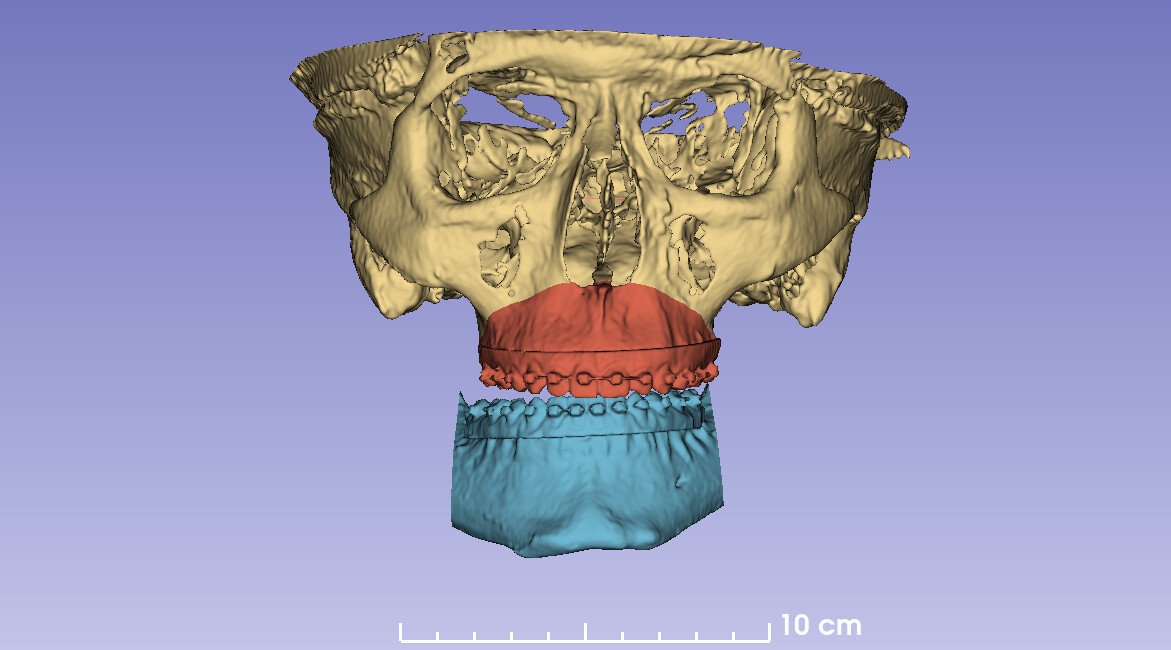
```auto
56 Collisions Detected
(True, 56)
```
---
### Author:  [@mau\_igna\_06](https://discourse.slicer.org/u/mau_igna_06)
#### Post date: [September 12, 2021, 11:50pm UTC](https://discourse.slicer.org/t/collision-detection/19635/2 "2021-09-12T23:50:17Z")
> **vtkSlicerRtCommonPython.vtkCollisionDetectionFilter()** kept giving the missing attribute error
This happens because you need to install SlicerRT extension to use that class. But `vtk.vtkCollisionDetectionFilter()` class was added to Slicer core in recent Slicer Preview releases (it is the same filter)
---
### Author:  [@lassoan](https://discourse.slicer.org/u/lassoan)
#### Post date: [September 13, 2021, 2:17pm UTC](https://discourse.slicer.org/t/collision-detection/19635/3 "2021-09-13T14:17:01Z")
We had to remove vtkCollisionDetectionFilter from SlicerRT as it was not necessary anymore and it interfered with the one that is in VTK.
---
### Author:  [@mau\_igna\_06](https://discourse.slicer.org/u/mau_igna_06)
#### Post date: [September 13, 2021, 2:56pm UTC](https://discourse.slicer.org/t/collision-detection/19635/4 "2021-09-13T14:56:31Z")
> We had to remove vtkCollisionDetectionFilter from SlicerRT as it was not necessary anymore and it interfered with the one that is in VTK.
Does SlicerRT on the Slicer Stable release have this filter? BoneReconstructionPlanner uses this filter and currently only works on Slicer Stable Release.
Some functions BRP used changed name on preview release. Maybe I can have two different branches, one for each release type, if the answer to the question above is yes
---
### Author:  [@lassoan](https://discourse.slicer.org/u/lassoan)
#### Post date: [September 13, 2021, 3:05pm UTC](https://discourse.slicer.org/t/collision-detection/19635/5 "2021-09-13T15:05:32Z")
Slicer Stable Release (Slicer-4.11.20210226) uses VTK-8.2, which does not contain vtkCollisionDetectionFilter, so there SlicerRT provides it.
Usually we try to keep the same extension source code to work with the latest Slicer Stable Release and Slicer Preview Release and manage small API differences using if/else or try/except blocks. If this gets too complicated (e.g., in case of vtkCollisionDetectionFilter we should have moved the filter into a separate library to prevent the header files from clashing, which would have been too much work) then we create a separate branch, which usually means that the stable branch does not get any more updates (because we don’t have time to backport and test all changes).
---
### Author:  [@tsims](https://discourse.slicer.org/u/tsims)
#### Post date: [September 16, 2021, 2:54pm UTC](https://discourse.slicer.org/t/collision-detection/19635/6 "2021-09-16T14:54:22Z")
Just wanted to jump into this thread, I implemented the code that Fluvio discussed above, and it seems to be working only when the transforms are hardened and won’t use geometry location if it is observing a transform node. Is there any way to make the vtkCollisionDetectionFilter observe a transform node?
---
### Author:  [@mau\_igna\_06](https://discourse.slicer.org/u/mau_igna_06)
#### Post date: [September 16, 2021, 6:00pm UTC](https://discourse.slicer.org/t/collision-detection/19635/7 "2021-09-16T18:00:13Z")
I would modify the function like this:
```auto
def findMeshCollision( node1, node2, verbose=False ):
'''
Find Mesh Collision
This function finds a collision or intersection between two surface meshesu=fluvio_lobo
'''
#
# Variables
#collisionDetection = vtkSRCP.vtkCollisionDetectionFilter()
collisionDetection = vtk.vtkCollisionDetectionFilter()
numberOfCollisions = 0
collisionFlag = False
#
# Collision Detection
node1ToWorldTransformMatrix = vtk.vtkMatrix4x4()
node2ToWorldTransformMatrix = vtk.vtkMatrix4x4()
node1ParentTransformNode = node1.GetParentTransformNode()
node2ParentTransformNode = node2.GetParentTransformNode()
if node1ParentTransformNode != None:
node1ParentTransformNode.GetMatrixTransformToWorld(node1ToWorldTransformMatrix)
if node2ParentTransformNode != None:
node2ParentTransformNode.GetMatrixTransformToWorld(node2ToWorldTransformMatrix)
#
collisionDetection.SetInputData( 0, node1.GetPolyData() )
collisionDetection.SetInputData( 1, node2.GetPolyData() )
collisionDetection.SetMatrix( 0, node1ToWorldTransformMatrix )
collisionDetection.SetMatrix( 1, node2ToWorldTransformMatrix )
collisionDetection.SetBoxTolerance( 0.0 )
collisionDetection.SetCellTolerance( 0.0 )
collisionDetection.SetNumberOfCellsPerNode( 2 )
collisionDetection.Update()
#
numberOfCollisions = collisionDetection.GetNumberOfContacts()
if numberOfCollisions > 0:
collisionFlag = True
else:
collisionFlag = False
#
# Status Verbose
if(verbose):
if(collisionFlag == True ):
print( "{} Collisions Detected".format( numberOfCollisions ) )
else:
print( "No Collisions Detected" )
#
# Return;
return collisionFlag, numberOfCollisions
```
Hope it helps